Application · Bin Picking
Bin Picking
Pick parts quickly and accurately using vision-guided robots. 3D vision + AI for unstructured environments — including translucent objects, variable containers, and full operator autonomy.
What we automate
Picking anything, from anywhere
Bin picking applications require precise part detection and handling, often in unstructured environments. Our system supports 3D vision setups, either mounted on the robot end-effector or fixed in the workspace, enabling flexible operation alongside existing robot flows. Accurate part identification, efficient grasp planning, and parallel execution with other processes — increasing throughput while reducing errors.
- Fixed camera and end-effector camera configurations
- Works with transparent and translucent objects
- AI grasp planning for variable part geometries
- Parallel execution with existing robot processes
- Operators add new container types without any programming
Real Use Case · In Production
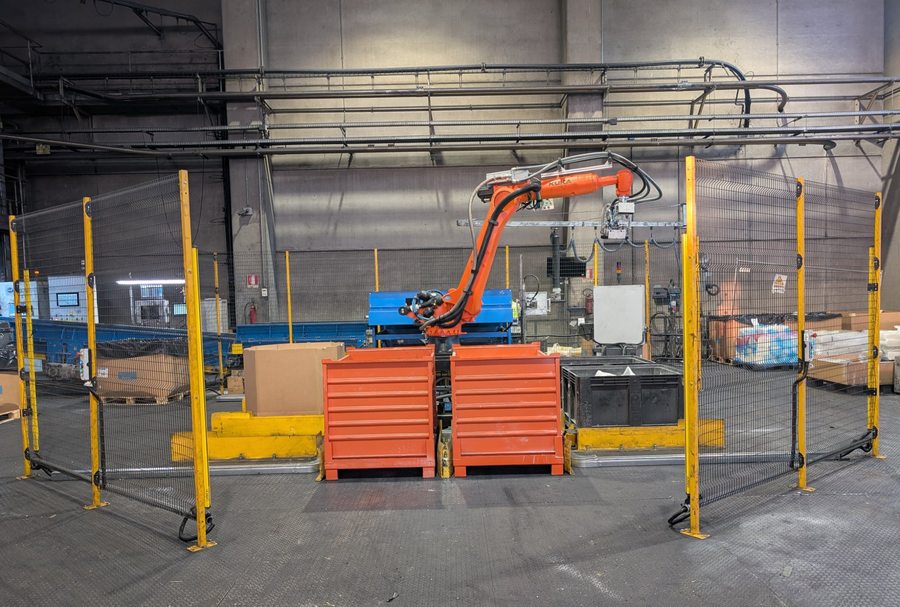
Translucent Bag Bin Picking
3D vision + AI to pick translucent bags ranging from 1.5 to 12 kg across 50+ container types. The system handles highly unstructured environments with full operator autonomy — operators add new container types themselves, from the 3D configurator. NVIDIA hardware enables real-time AI inference even in the most complex picking scenarios.
Read Zivid's bin picking case study
Operator interface · In production
The operator's view
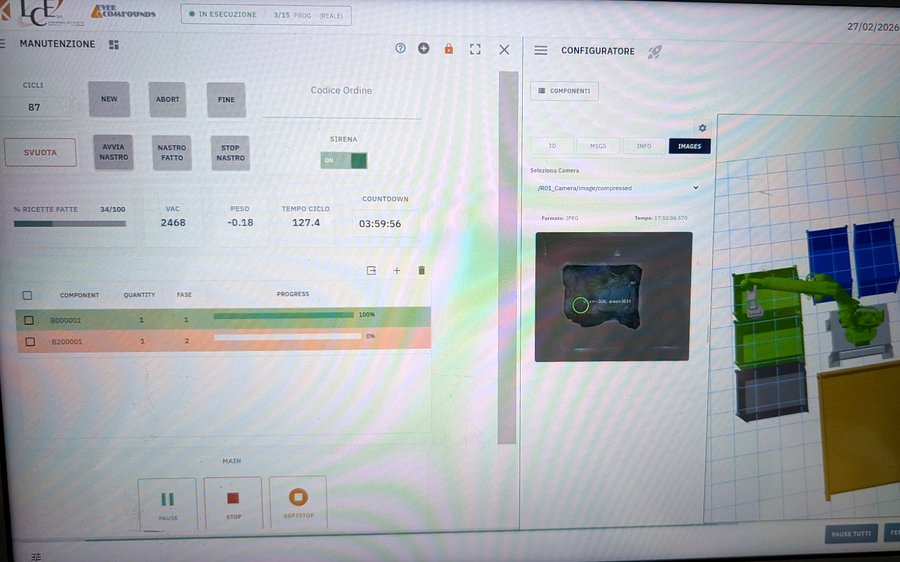
The YK Portal runs directly on the cell's touchscreen panel. The operator sees live cycle counts, component progress, camera feed, and the 3D configurator — all from a single interface generated automatically by the platform. No custom HMI development required.
- Live camera feed with AI detection overlay
- Cycle counter, production progress per component
- 3D configurator: add container types without programming
- Full operator autonomy — no robotics expertise needed


